ENGINEERING ARCHIVES
Autonomous Mobile Robots, Sim-to-Real Digital Twins, and Embedded Hardware Systems
AUTOMATED JEKYLL DOCUMENTATION ECOSYSTEM
Every production ROS 2 package, space robotics model, and edge AI pipeline is accompanied by automated architectural specifications and deployment blueprints hosted under our custom engineering documentation hub.
Orbital ADR: Autonomous Space Debris Cleaning Robot
Active Debris Removal (ADR) & Orbital Logistics Platform (Smart India Hackathon 2026 — PS SIH26226)
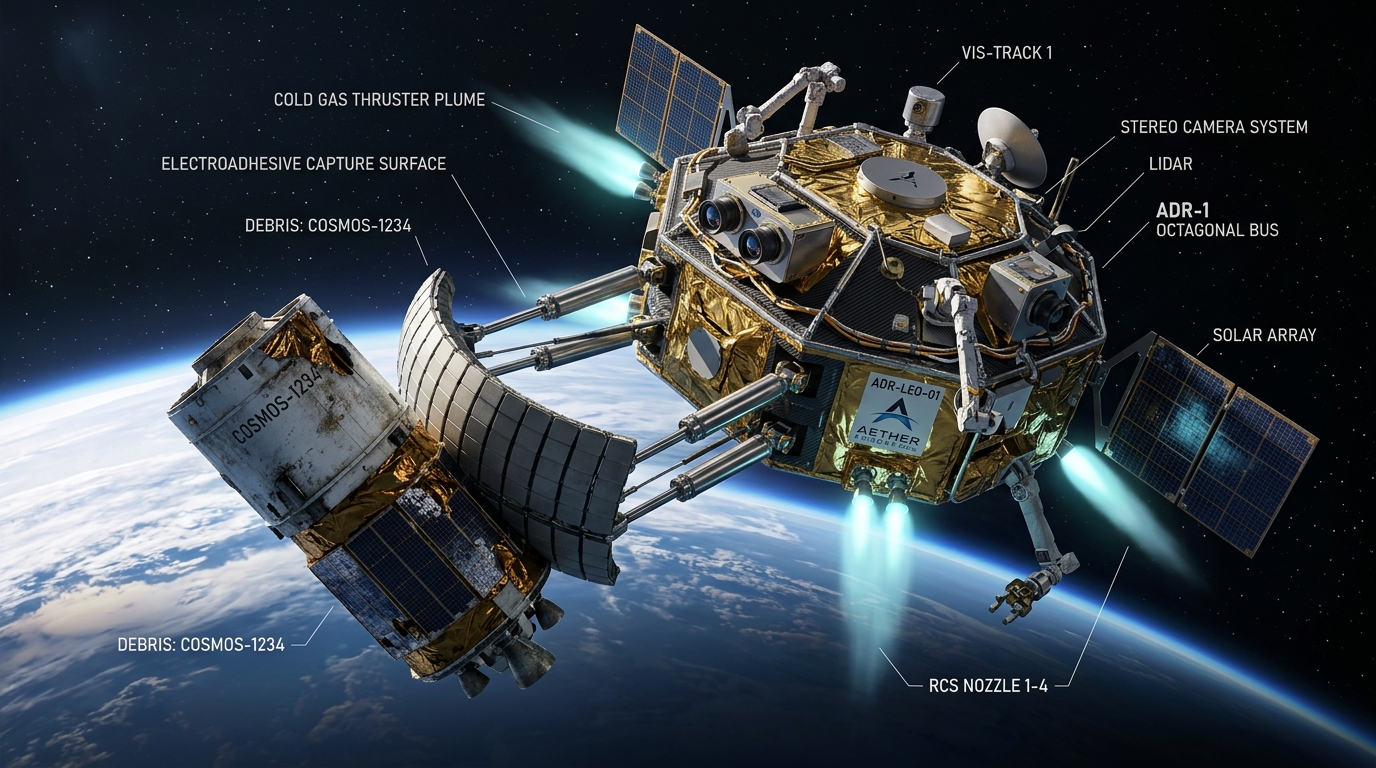
Engineered an autonomous Active Debris Removal (ADR) spacecraft architecture designed for Low Earth Orbit (LEO) debris remediation under SIH Problem Statement SIH26226. Combines a custom octagonal CAD bus with a 4-piston mechanical Compression System to dampen docking kinetics, alongside an electroadhesive capture plate capable of gripping non-conductive, irregular space debris. Uses a segregated dual-compute architecture: NVIDIA Jetson Nano running ROS 2 and SpaceYOLO for non-cooperative tumbling target pose estimation, linked to an STM32 MCU for microsecond cold-gas thruster firings, backed by a live Three.js orbital mission control interface.
- Designed 3-phase orbital flight plan: autonomous chaser rendezvous, mothership deployable deorbit braking modules, and reusable orbital tug logistics.
- Bypassed traditional magnetic grapple limitations using high-voltage electroadhesion to adhere to carbon fiber, composite casings, and glass.
- Deployed an interactive WebGL mission control simulator providing real-time 3D telemetry and docking trajectory visualization.
EdgeVision NPU Profiler
Bare-Metal On-Device Edge AI Evaluation Testbench (iQOO Hackathon 2026 Grand Finale)
Eliminates the deployment bottleneck between desktop AI training and physical mobile/edge hardware. Turns commercial Snapdragon NPU smartphones into live bare-metal evaluation testbenches, executing custom .tflite and ONNX models directly on NPU tensor cores using native camera streams with real-time latency and memory telemetry streaming back to a desktop terminal.
- Integrated a zero-cable wireless sync bridge to drag-and-drop compiled models directly from laptop to device.
- Bypassed CPU bottlenecks with a zero-copy native camera pipeline delivering 30–60 FPS video frames straight into the NPU buffer.
- Built a live telemetry stream monitoring true inference latency (ms), frame rate stability, and thermal limits.
Hybrid Vortex Crawler: Multi-Surface Wall-Climbing Robot
Engineered an industrial wall-climbing inspection robot utilizing an active aerodynamic vortex 70mm Electric Ducted Fan (EDF) generating 45 N holding force combined with passive N52 magnetic track locking. Implemented a dual-tier control hierarchy: ROS 2 Jazzy on Raspberry Pi 4 for high-level mission logic and ToF telemetry, paired via UART to an ESP32 FreeRTOS controller for deterministic motor actuation and 50Hz tilt stabilization.
AutoTwin-AI: Spatiotemporal ConvLSTM Welding Inspection
Upgraded AutoTwin-AI from static frame inspection to an in-situ spatiotemporal video deep learning framework for robotic arc welding cells. Ingests 30 FPS thermal video streams as 5D tensors (Batch, Time, Channels, Height, Width) from an end-effector mounted LWIR camera tracking the Tool Center Point (TCP). Uses TimeDistributed CNNs and ConvLSTM2d recurrent cells for unsupervised next-frame prediction; sudden Mean Squared Error (MSE) divergences detect subsurface voids, spatter bursts, and cooling rate anomalies in under 40ms, synchronized with a real-time Three.js 3D digital twin HUD.
OOMWOO: Autonomous Robot Vacuum System
Authored core open-source coverage planning modules for the OOMWOO autonomous vacuum robot (oomwoo_clean_and_map). Implemented Boustrophedon Cellular Decomposition (BCD) for complete workspace coverage and integrated SLAM Toolbox for online map generation and localization under ROS 2 Jazzy.
Smart Traffic Management System (SIH25050)
Built a vision-based adaptive traffic signal controller utilizing YOLO object detection to dynamically calculate vehicular queue density across multi-lane intersections and modulate green-light intervals.
Hybrid AI Scholarship Policy Engine
Engineered an anomaly detection and policy verification bot designed to automate scholarship eligibility parsing, document fraud detection, and compliance auditing with an interactive Streamlit UI.
EcoCast AI: Schneider Electric Melter Optimizer
Engineered an AI-driven energy and thermal scheduling engine for industrial induction melters. Models temperature ramp profiles and molten metal cooling curves to minimize electrical surge penalties and heat loss during batch cycles.
Twindeo: Federated 3D Industrial Digital Twin
Built a federated digital twin engine streaming live 3D joint states, kinematics, and spatial heatmaps from multi-robot manufacturing workcells into a low-latency WebGL browser HUD.
4WD Autonomous Mobile Robot (Gazebo + FSM)
Engineered an open-source 4-wheel differential-drive autonomous rover package for ROS 2 Jazzy. Features custom URDF physical modeling, Gazebo friction plugins, and an autonomous behavior finite-state machine (FSM).
Luminous Inverter PdM Command Center
Telemetry command center monitoring capacitor degradation, thermal stress, and voltage harmonics across solar and industrial inverters to trigger automated maintenance before failure.
ROS 2 Real-Time Odometry Drift Monitor
Zero-copy C++ node monitoring real-time discrepancies between wheel encoder odometry and IMU angular rate integration, broadcasting diagnostic alerts on ROS 2 /diagnostics before localization divergence occurs.
RESEARCH & PUBLICATIONS
Indexed Preprints, DOI Registrations & Multi-Agent RL Formulations
Sensor-Fusion Driven Deep Reinforcement Learning for Dynamic Traffic Signal Optimization
Author: Deepak R • Zenodo Preprint
This paper presents a closed-loop, decentralized urban traffic management architecture integrating real-time computer vision telemetry with multi-agent reinforcement learning (MARL). By ingesting optical density metrics and vehicle queue trajectories, the policy dynamically adjusts signal timing to maximize arterial throughput while minimizing waiting variance.
- Closed-loop telemetry pipeline fusing edge vision detections directly into policy state space.
- Multi-agent reward formulation preventing congestion spillover across adjacent intersections.
- Open access publication and dataset schema indexed under Zenodo DOI 10.5281/zenodo.20265628.
AURA: Acoustic-visual Urban Routing Architecture for Autonomous Mobile Robots
Author: Deepak R • Target: ICRA / IROS Conference Series
Investigating multimodal acoustic and visual sensor fusion frameworks to facilitate robust autonomous robot navigation and localized spatial awareness in GPS-denied, visually degraded urban canyons.
- Cross-modal acoustic-visual feature extraction for spatial landmark localization.
- Integration with ROS 2 Nav2 costmaps and real-time state estimators.
TECHNICAL LICENSES & CERTIFICATIONS
Industrial Robotics Career Programs, IBM Machine Learning & Linux Systems
Supervised Learning Methods
IBM
Data Analysis Using Python
IBM
Unsupervised Learning Methods
IBM
CTS Jan 26 Badge
Google Cloud Skills Boost
Digital Circuits
NPTEL
NPTEL25EE125S1154009277Industrial Robotics Theories for Implementation
NPTEL
NPTEL25ME161S1254009474Artificial Intelligence Fundamentals
IBM
Computer Hardware Basics
Cisco
Joy of Computing using Python
NPTEL
Weekly Coding Challenge 26
Unstop
3dc431aa-a8db-4827-9b74-40e00d356b9bCreate a Promotional Video using Canva
United Latino Students
MJL10F4I8EX0Certified Basic Resume Writer
TCS iON
Build a free website with WordPress
Coursera
RDD8RJ6MWZEUPearson MePro Level 10 Expert
Pearson
Introduction to Programming Using Python
upGrad
cb560194-63da-4524-898b-8d57b772a149